Damping and Resonance
Specification: OCR A H556 | Section: 5.3.3 | Teaching time: ~4 hours
- Distinguish between free oscillations and forced oscillations
- Describe the effects of damping on an oscillatory system, including light, heavy and critical damping
- Explain resonance and identify the natural frequency of an oscillator
- Sketch and interpret amplitude–driving frequency graphs for forced oscillators with different amounts of damping
- Describe practical examples of forced oscillations and resonance, including Barton's pendulums
- Explain how damping affects the resonant frequency and the time period of an oscillating system
Free and Forced Oscillations
Before we can understand damping and resonance, we need to distinguish between two fundamentally different ways an oscillator can move.
Free Oscillations
A free oscillation occurs when a system oscillates at its natural frequency f0 with no external driving force after an initial displacement. The frequency depends only on the physical properties of the system — for a mass–spring system, f0 = (1/2π)√(k/m); for a simple pendulum, f0 = (1/2π)√(g/L).
In practice, all free oscillations are eventually damped by friction or air resistance, but we describe them as "free" when no external periodic force is being applied.
Forced Oscillations
A forced oscillation occurs when a periodic external driving force is applied to a system. The system oscillates at the driving frequency fd, which may be different from the natural frequency.
Free oscillation: system vibrates at its own natural frequency after being displaced and released.
Forced oscillation: system is made to vibrate by an external periodic force at the driving frequency.
The natural frequency is sometimes called the resonant frequency — the frequency at which a system "wants" to vibrate when left alone.
Damping
Damping is the process by which the amplitude of an oscillation decreases over time. Energy is transferred from the oscillating system to the surroundings (usually as thermal energy due to friction or drag). In all real systems, some damping is present.
Levels of Damping
A useful qualitative comparison has three categories of damping. They differ in how quickly the system returns to equilibrium and whether it overshoots.
| Type | Behaviour | Example |
|---|---|---|
| Light damping | Oscillates with gradually decreasing amplitude. Takes many cycles to die out. | Car suspension, pendulum in air |
| Critical damping | Returns to equilibrium in the shortest possible time without oscillating. | Car shock absorbers, galvanometer |
| Heavy (over-) damping | Returns to equilibrium very slowly without oscillating. Slower than critical damping. | Door with very stiff closer, overdamped scales |
Displacement–Time Graphs
The graph below shows how displacement varies with time for each type of damping, starting from the same initial displacement.
Heavy damping does not mean the oscillation stops sooner. Heavy damping returns to equilibrium more slowly than critical damping. Critical damping is the optimum — fastest return without overshooting.
Figure 1 — Displacement–time graphs for a damped oscillator. Light damping (blue) shows decaying oscillations. Critical damping (orange) returns to equilibrium fastest without overshooting. Heavy damping (red) returns to equilibrium more slowly than critical.
Knowledge Check
- Free oscillation: system oscillates at its natural frequency without a periodic external force ✓
- Forced oscillation: system is driven by an external periodic force at the driving frequency ✓
- Critical damping returns the system to equilibrium in the shortest possible time ✓
- Without oscillating / overshooting — the car doesn't bounce up and down repeatedly after a bump ✓
- Total energy decreases over time as energy is transferred to the surroundings (e.g. as thermal energy) ✓
Resonance
Displacement resonance is a peak in the steady response amplitude as driving frequency changes. For weak damping the peak lies close to the undamped natural frequency, fd ≈ f0. In the linear viscous model, maximum average input power occurs at f₀ while the displacement peak lies slightly below f₀. Sufficiently strong damping removes the nonzero-frequency displacement peak.
How Resonance Works
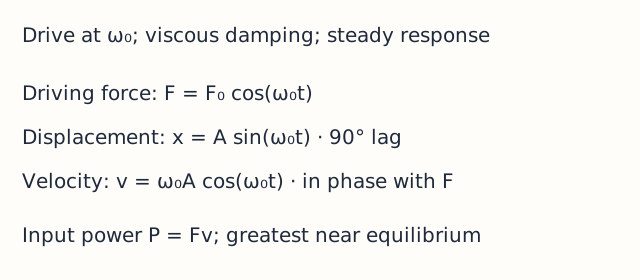
When you push a child on a swing, you push at the right moment each cycle. If you push at the natural frequency of the swing, an appropriately timed push adds energy while force and velocity point in the same direction. Instantaneous input power P = Fv is greatest near equilibrium where the speed is largest; it is zero at a turning point where v = 0. The amplitude grows with each cycle.
If you push at a different frequency, sometimes you push when the swing is already moving away — your push might even slow it down. The amplitude stays small.
Amplitude–Driving Frequency Graphs
The resonance curve (also called a response curve) shows how the amplitude of a forced oscillator depends on the driving frequency. The shape of the curve depends critically on the amount of damping.
- Light damping → a sharp, tall peak close to f0. Small changes in frequency cause large changes in amplitude.
- Increased damping → lower, broader peak, until sufficiently strong damping removes the nonzero-frequency peak.
- No damping → the ideal resonant response grows with time; there is no finite steady amplitude.
The graph below shows resonance curves for different levels of damping.
For the fixed-force linear model, damping reduces the steady displacement amplitude at nonzero driving frequencies; its zero-frequency static displacement is unchanged. But the effect is most dramatic near the peak — light damping produces a much taller peak than heavy damping.
Figure 2 — Resonance curves for a forced oscillator. Light damping (blue) gives a sharp peak with large maximum amplitude. Greater damping broadens and lowers any displacement peak; the overdamped red curve has no nonzero-frequency peak. The dashed line marks the undamped natural frequency f₀, not every curve's peak.
Knowledge Check
- The maximum amplitude at resonance decreases ✓
- The resonance curve becomes broader / less sharp ✓
- At a drive of f₀, the steady velocity is in phase with the driving force [1]
- For fixed driving-force amplitude, average input power reaches its maximum at f₀ in this viscous model [1]
- For weak damping the displacement peak is close to f₀; it is slightly below f₀ in the exact model, so the two maxima are not identical [1]
Damping, Resonance and Time Period
So far we have treated damping and resonance separately. In reality, they are deeply connected. When a system is damped, both its behaviour at resonance and its effective time period change.
Free response: when is a period defined?
Undamped motion has T₀ = 2π/ω₀. Lightly damped motion still oscillates: its amplitude decreases and its period is approximately T₀. With stronger underdamping, the period increases. A critically damped or overdamped free response does not oscillate, so an oscillation period is not defined.
OCR 5.3.3 centres on free/forced motion, damping, resonance and response graphs. The following linear viscous model is an optional mathematical extension, not a required formula.
For 0 ≤ γ < ω₀ only: ωfree = √(ω₀² − γ²); Tfree = 2π/ωfree.
γ = ω₀: critical, no period. γ > ω₀: overdamped, no period.
Driven displacement resonance is a different frequency
In steady forced motion, the oscillator moves at the driving frequency. For weak damping its displacement-amplitude peak is close to the undamped natural frequency f₀. For the same linear model, ωpeak = √(ω₀² − 2γ²) only when γ < ω₀/√2. At or above this threshold there is no nonzero-frequency displacement peak. This is not the damped free frequency √(ω₀² − γ²).
Practical Examples of Resonance
Barton's Pendulums
This is the classic demonstration of resonance for A Level. Several pendulums of different lengths hang from a taut string. One "driver" pendulum is pulled back and released — it drives all the others through the connecting string.
- The pendulum whose length matches the driver oscillates with the largest amplitude (resonance)
- Pendulums with different lengths oscillate with smaller amplitudes
- The core observation is the largest amplitude at matching length; phase requires a defined driving force
- In an ideal force-driven oscillator well below its own natural frequency, displacement is approximately in phase with the driving force
- Well above its own natural frequency, displacement is approximately in antiphase with force. At a drive of ω₀ it lags force by 90°; velocity is in phase with force. The connecting string's force is not automatically in phase with the driver pendulum's displacement.
Other Examples
- Radio tuning — an LC circuit is tuned to resonate at the frequency of the desired radio station
- Musical instruments — the body of a guitar resonates at certain frequencies, amplifying specific notes
- MRI scanners — use resonance of protons in a magnetic field
- Tacoma Narrows Bridge (1940) — aeroelastic flutter (a self-excited instability, distinct from simple externally forced resonance) caused the bridge to oscillate with increasing amplitude until it collapsed
- Vibration in vehicles — engine vibrations at certain RPMs can cause resonance in panels and mirrors
- Glass shattering with sound — a singer matching the natural frequency of a wine glass can cause it to resonate and break
Resonance can be dangerous. The amplitude at resonance can become so large that the system is damaged or destroyed. This is why engineers design structures to avoid resonant frequencies matching common driving forces (wind, traffic, earthquakes). Damping is deliberately added to reduce the resonant amplitude.
Damping Explorer
A mass is released from displacement and allowed to oscillate freely. Adjust the damping to see how it affects the decay. All three curves are plotted simultaneously so you can compare light, critical and heavy damping.
Resonance Explorer
A rotating cam drives a mass–spring system. Adjust the cam frequency and watch how the amplitude of oscillation changes. For weak damping, the response peak is close to the natural frequency. The display uses a force-driven linear-oscillator model with a fixed undamped f₀; its phase readout is displacement relative to driving force. The curve records the exact predicted steady amplitude for each selected frequency and the current damping. A real oscillator must settle after each change: in this underdamped model, wait at least 5/γ seconds for the transient envelope to fall below 1% of its initial value. Here we assume that transient has decayed before each point; these are model predictions, not transient measurements. Changing damping clears the previous curve.
Exam-Style Questions
(a) Which of the other pendulums will oscillate with the largest amplitude? Explain your answer.
(b) In the ideal steady linear oscillator model driven at its undamped natural frequency, state the phase of the responding displacement relative to the periodic driving force.
- (a) The pendulum with length 40.0 cm (same length as the driver) ✓
- Its natural frequency matches the driving frequency, close to the displacement resonance peak for weak damping [1]
- Energy input builds a large steady response until average input balances dissipation; the weak-damping peak is close to f₀ [1]
- (b) Responding displacement lags the specified driving force by 90°. The velocity is in phase with that force; this is not a claim about the two pendulums' displacements ✓
(a) Sketch a graph of amplitude against driving frequency for this system with (i) light damping and (ii) increased damping that still allows a resonance peak. Label the undamped natural frequency on your graph. [4 marks]
(b) Describe the effect of sufficiently strong damping on the displacement resonance peak. [1 mark]
- (a) Amplitude on the y-axis and driving frequency on the x-axis [1]
- Light damping: tall, narrow peak [1]
- Increased damping: lower, broader peak [1]
- f0 labelled independently of the peaks; lightly damped peak near f₀ [1]
- (b) Sufficiently strong damping removes the nonzero-frequency displacement peak [1]
- Unmarked extension: in the linear model this happens for γ ≥ ω₀/√2. Do not infer the driven peak from the free-oscillation period.
(a) Explain why the designer adds damping to the cone mechanism.
(b) The damping is increased. Describe two effects this has on the response of the cone across the frequency range.
- (a) Without damping, the cone would resonate strongly at 120 Hz ✓
- This would cause a large, unwanted peak in the frequency response, producing distortion and potentially damaging the cone ✓
- (b) The maximum amplitude at resonance decreases ✓
- The resonance peak becomes broader / the frequency response is more uniform across the range ✓
Extended Response (6 marks)
Discuss the physics of this situation. In your answer, you should:
• explain why the bridge vibrates dangerously
• describe what is meant by resonance in this context
• explain how adding dampers would reduce the problem
• discuss any disadvantages of adding significant damping
[6 marks, QWC]
- The marching troops apply a periodic driving force to the bridge at their stepping frequency ✓
- For weak damping, driving close to the natural frequency produces displacement resonance [1]
- Repeated energy input builds a large response until input and dissipation balance [1]
- Damping dissipates energy from the bridge's oscillations, reducing the steady response at positive driving frequencies for fixed drive force and stiffness [1]
- The resonance peak becomes lower and broader, so the bridge is less sensitive to any particular driving frequency ✓
- Dampers add cost and maintenance requirements and dissipate the vibration energy as heat ✓
Topic Summary
Free vs Forced
Free oscillations happen at the natural frequency. Forced oscillations occur at the driving frequency of an external periodic force.
Damping Types
Light: oscillates with decaying amplitude. Critical: fastest return to equilibrium, no oscillation. Heavy: slow return, no oscillation.
Resonance
With weak damping, the displacement peak is close to f₀. In the exact viscous model it lies below f₀, while average input power peaks at f₀. Increased damping lowers and broadens a surviving peak; static displacement at zero drive frequency is unchanged.
Damping Effects
Underdamping lengthens the free period; critical and overdamped responses have no period. Driven displacement peaks shift and can disappear with strong damping.